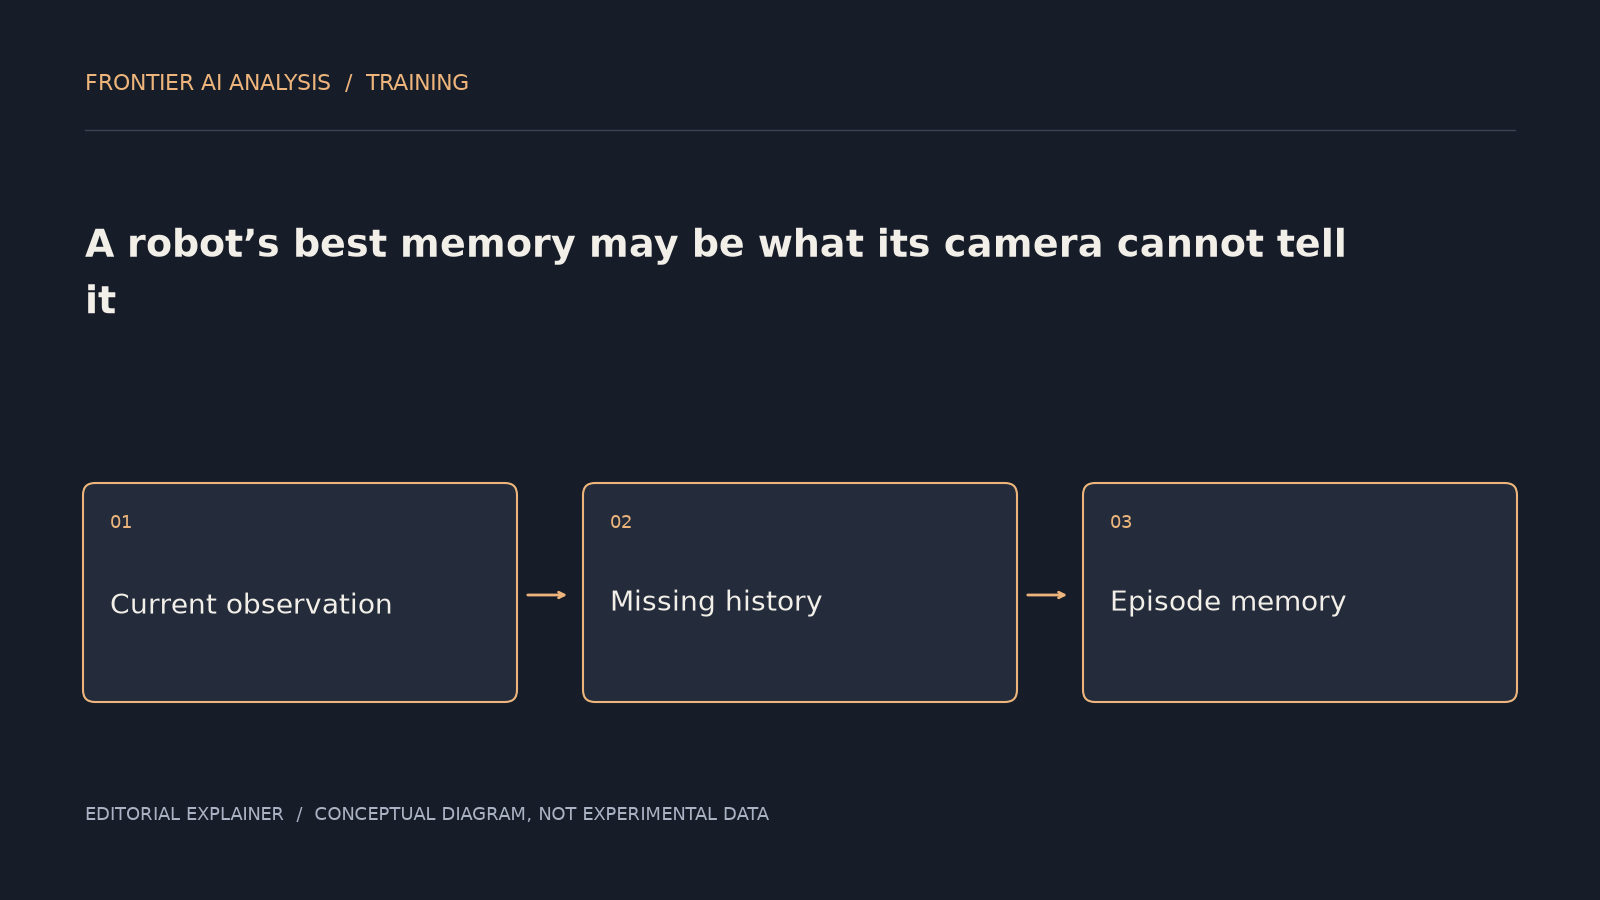
Imagine a robot returning to an open drawer. The image may show its contents perfectly. It may reveal nothing about whether the machine has already checked the compartment behind it.
That difference between seeing a state and remembering how it came about motivates an unusual memory design. TTT-RM, posted October 3 by researchers at the University of Illinois Chicago and Cisco Research, trains a memory to preserve historical information that the current observation and retrieved context cannot reconstruct. Its fast weights update during an episode and reset when the episode ends. The main policy weights stay fixed.
During training, a decoder supplies the reconstruction objective; it is discarded for deployment. The authors report improvements in task progress on their real-world tasks. The method is an episode memory mechanism, not evidence that a robot permanently teaches itself new skills while working.
An archive can be full of the present
The design offers a useful way to think about scarce memory. A recording of the last ten seconds may contain many nearly identical images of a table. If the current camera already shows the table, storing those images again competes with information that has disappeared: an earlier instruction, an object temporarily hidden from view or a completed stage of a task.
The important distinction is recoverability. A memory should not be judged only by how much of the past it retains. It should be judged by whether the retained information can change a decision that current sensing alone cannot resolve.
This suggests a more discriminating test than asking a policy to perform a longer task. Construct two histories that end in an almost identical view but require different next actions. If the robot acts differently for the right reason, its memory has supplied something the image did not. If both histories lead to the same choice, a large context window may be adding little practical information.
Temporary learning has a different failure mode
Fast weights can sound like an autonomous system rewriting itself without limits. Here the reset boundary matters. An episode-specific update is closer to maintaining working state than to replacing the robot’s general training. That makes it possible to ask concrete questions about when memory is initialised, invalidated and cleared.
There is still a difficult engineering problem. If a camera glitches or an operator interrupts a task, should the memory retain the preceding history? Clearing it may erase useful progress; keeping it may preserve an assumption that is no longer true. The correct answer depends on what counts as a new episode in the real workflow.
For a drawer-stowing robot, an operator moving items halfway through a run could make that boundary more consequential than the nominal memory size. The research points toward a narrower, more useful ambition than remembering everything: preserve the information that distinguishes otherwise identical presents, and know when that distinction has expired.
References
Questions, news tips or corrections? Contact [email protected].