

 Data
The useful robot video is the one whose contact actually works
EgoMatrix prioritises hand–object relationships over exact scene reconstruction, exposing a weakness in visual realism as a data-quality test.
The datasets, collection systems and curation methods that determine what a model can learn.
Datasets · Collection & data rigs · Synthetic data · Curation & labeling
9 articles
DataEgoMatrix prioritises hand–object relationships over exact scene reconstruction, exposing a weakness in visual realism as a data-quality test.
 Data
SoTa gives human and robot hands matching tactile layouts, moving part of the alignment problem into hardware.
 Data
A practical LeRobot guide exposes a trap in ranking demonstrations: difficult work can look like bad data.
 Data
TACROSS makes human touch easier to collect while keeping robot demonstrations responsible for action supervision.
 Data
Human demonstrations could reduce the experience robots must collect themselves. Buyers need proof that the data transfers to their robot, task and environment.
 Data
Pegasus 1.6 targets first-person footage used in physical-AI datasets. Faster annotation helps only if important actions and failures survive human review.
 Data
Training environments turn expert judgment into repeated lessons. Weak success checks can teach an agent to produce the right result through the wrong process.
 Data
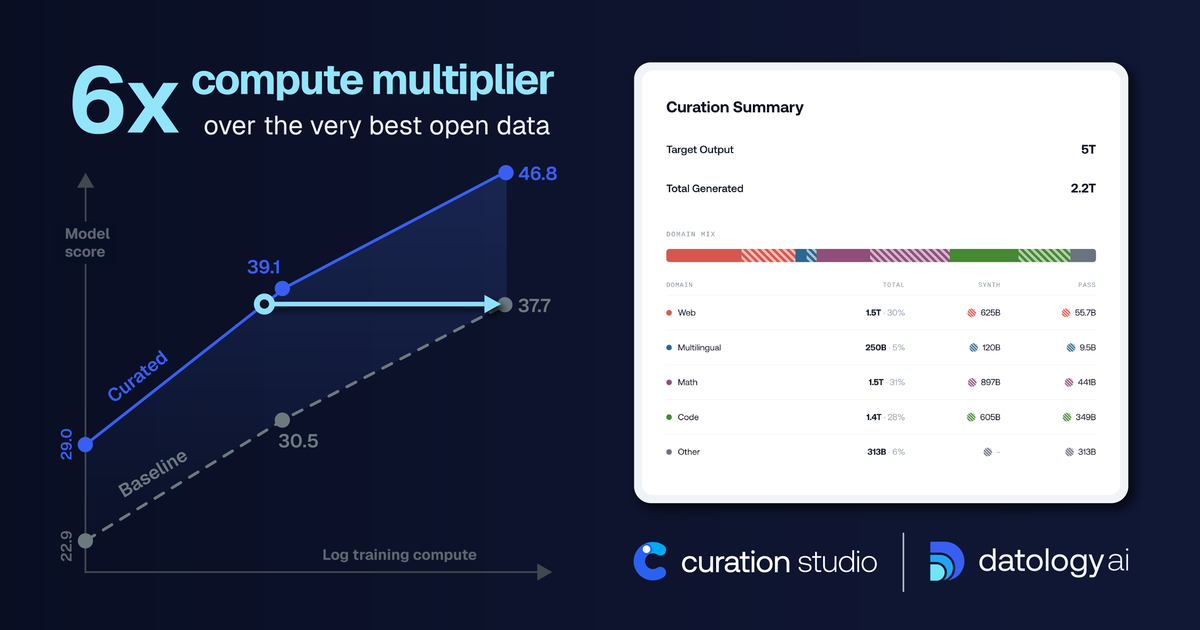
Curation Studio makes dataset selection a model-budget decision. The company’s reported compute saving is specific to its experiments; customers need a full-cost comparison.
 Data
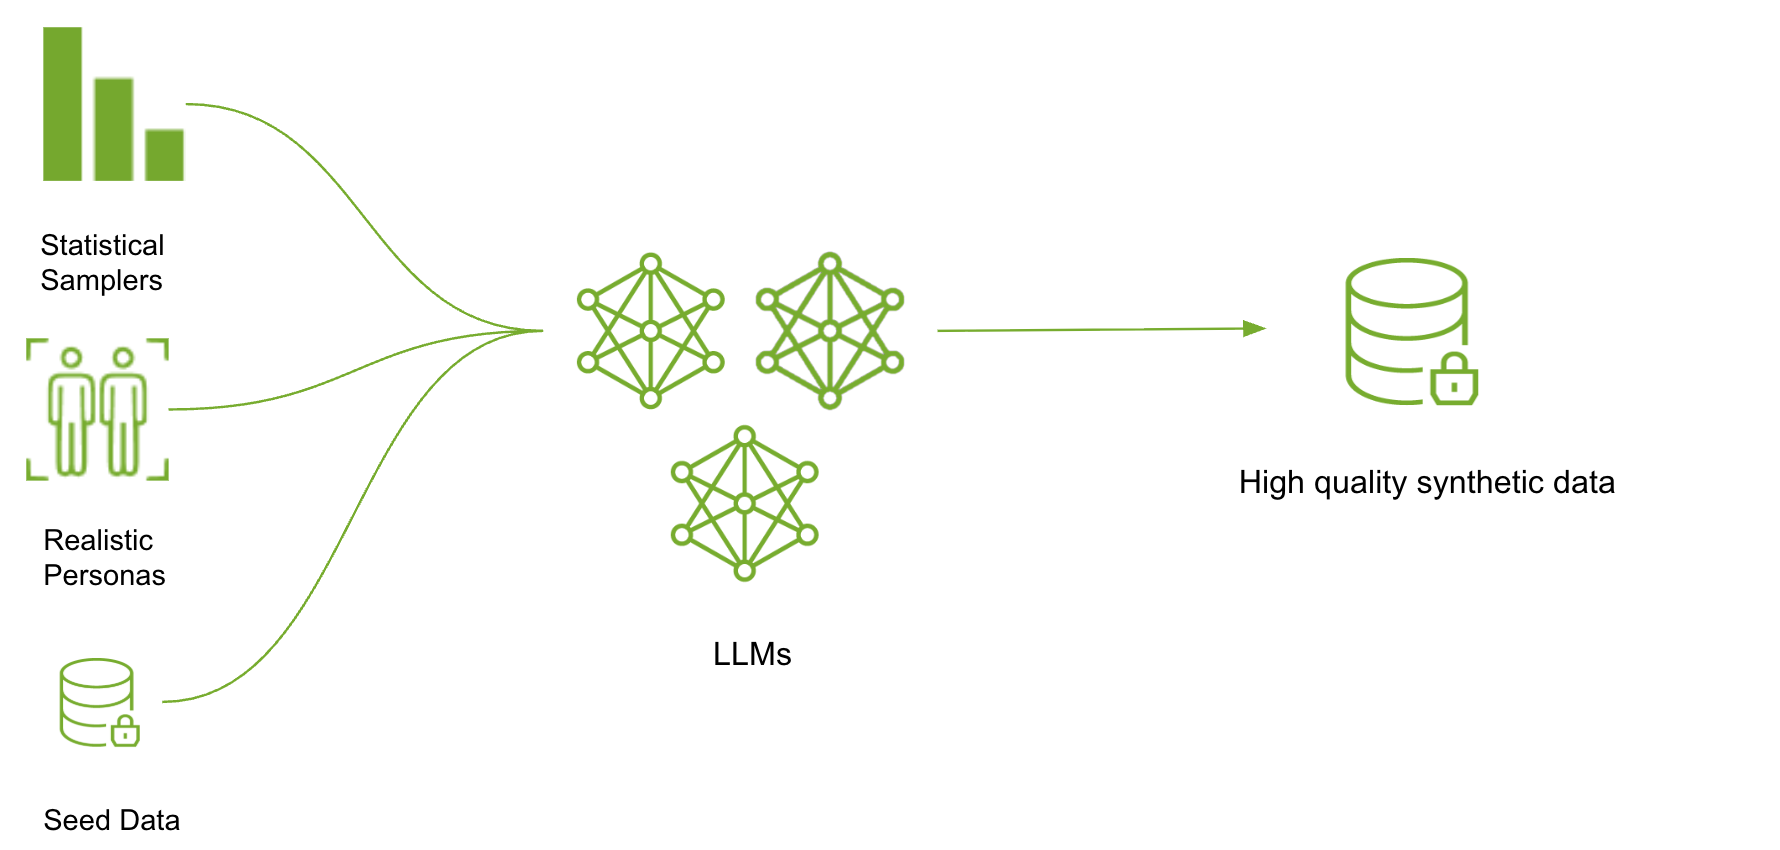
NeMo Data Designer makes fields, dependencies and checks explicit. The useful asset is a reproducible training-data recipe, not the number of generated rows.
Explore the other topics in this desk.