

 Inference
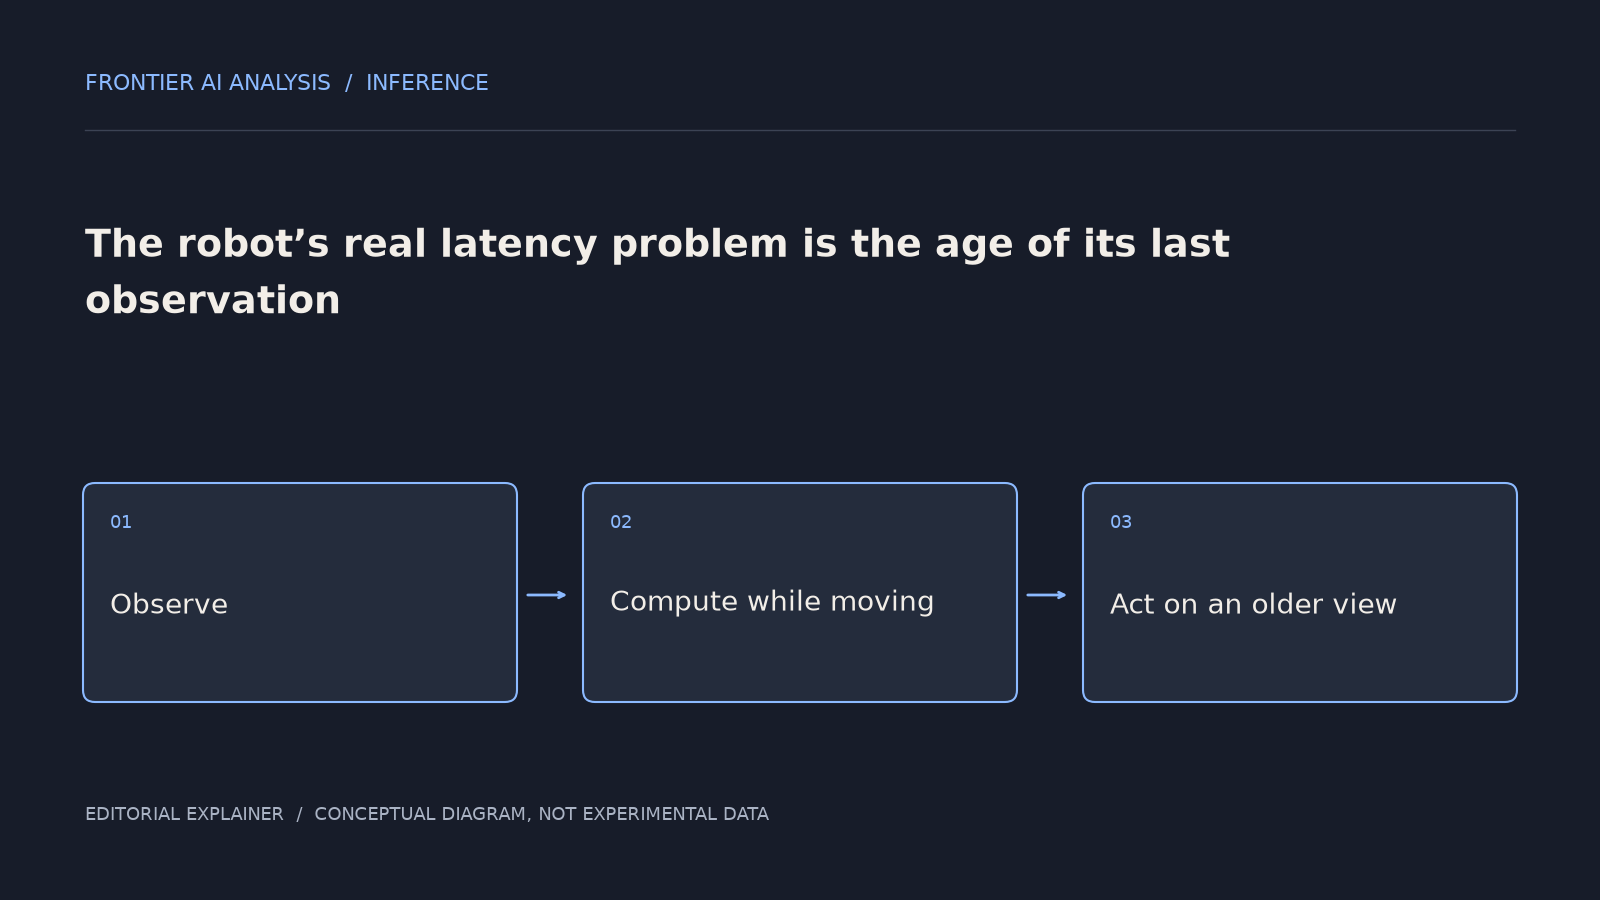
The robot’s real latency problem is the age of its last observation
A KAIST workload study shows why faster inference and more aggressive action overlap do not produce a single best operating point.
Model-building research and analysis covering KAIST.
InferenceA KAIST workload study shows why faster inference and more aggressive action overlap do not produce a single best operating point.
 Training
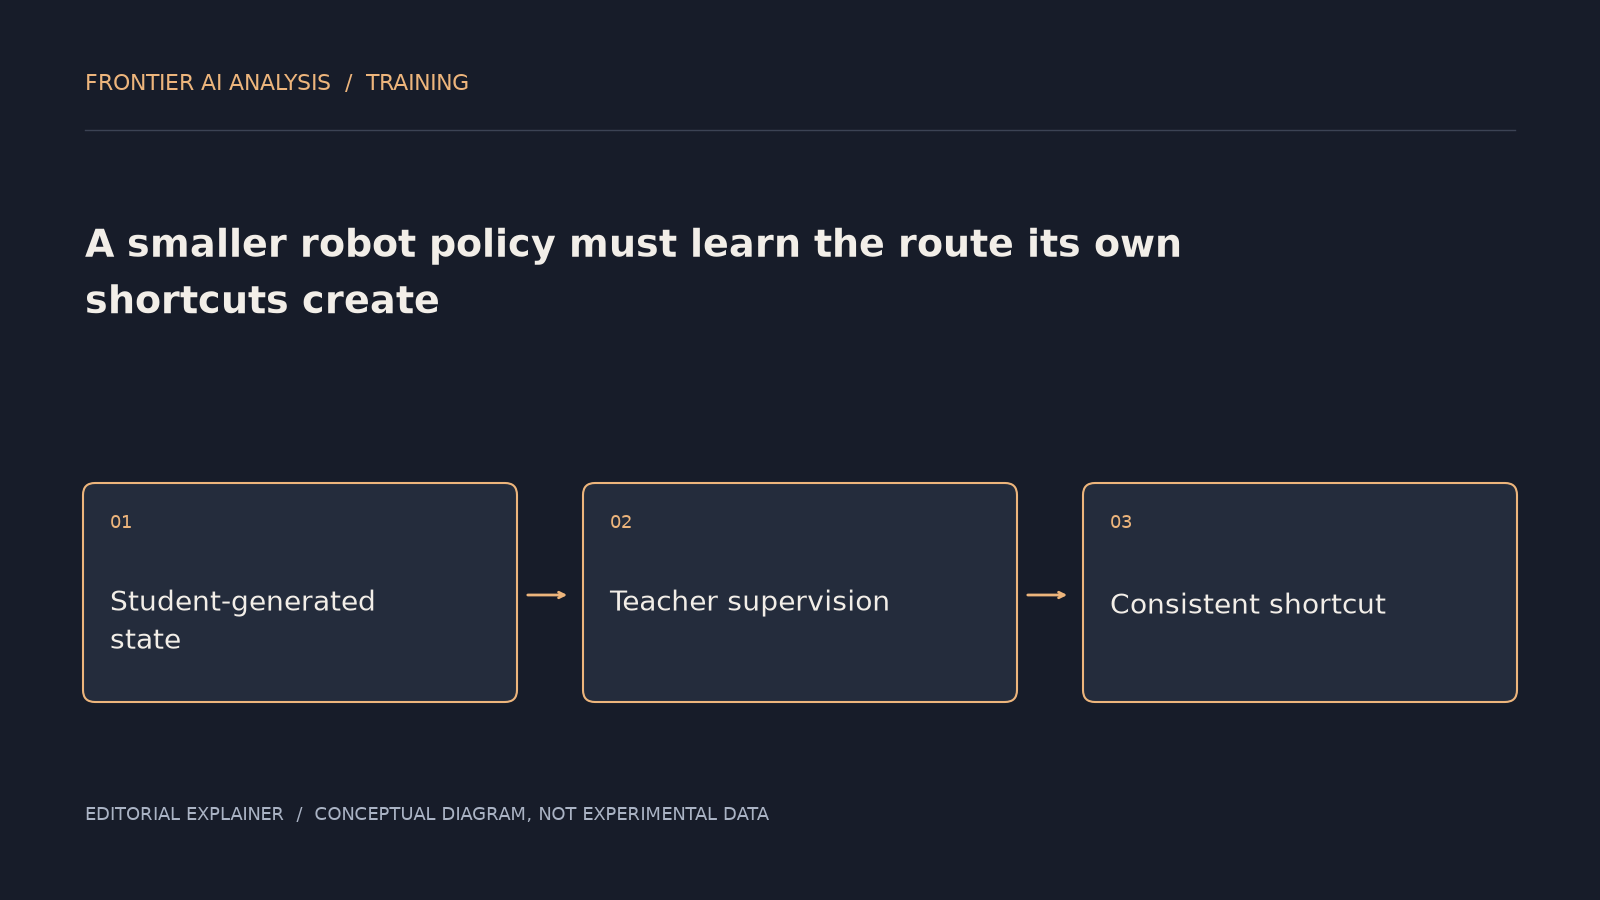
FastOPD reduces both model size and sampling steps. Its on-policy supervision addresses the states introduced by that compression.